How to Match Gearbox Ratios to Motor and Load Speeds
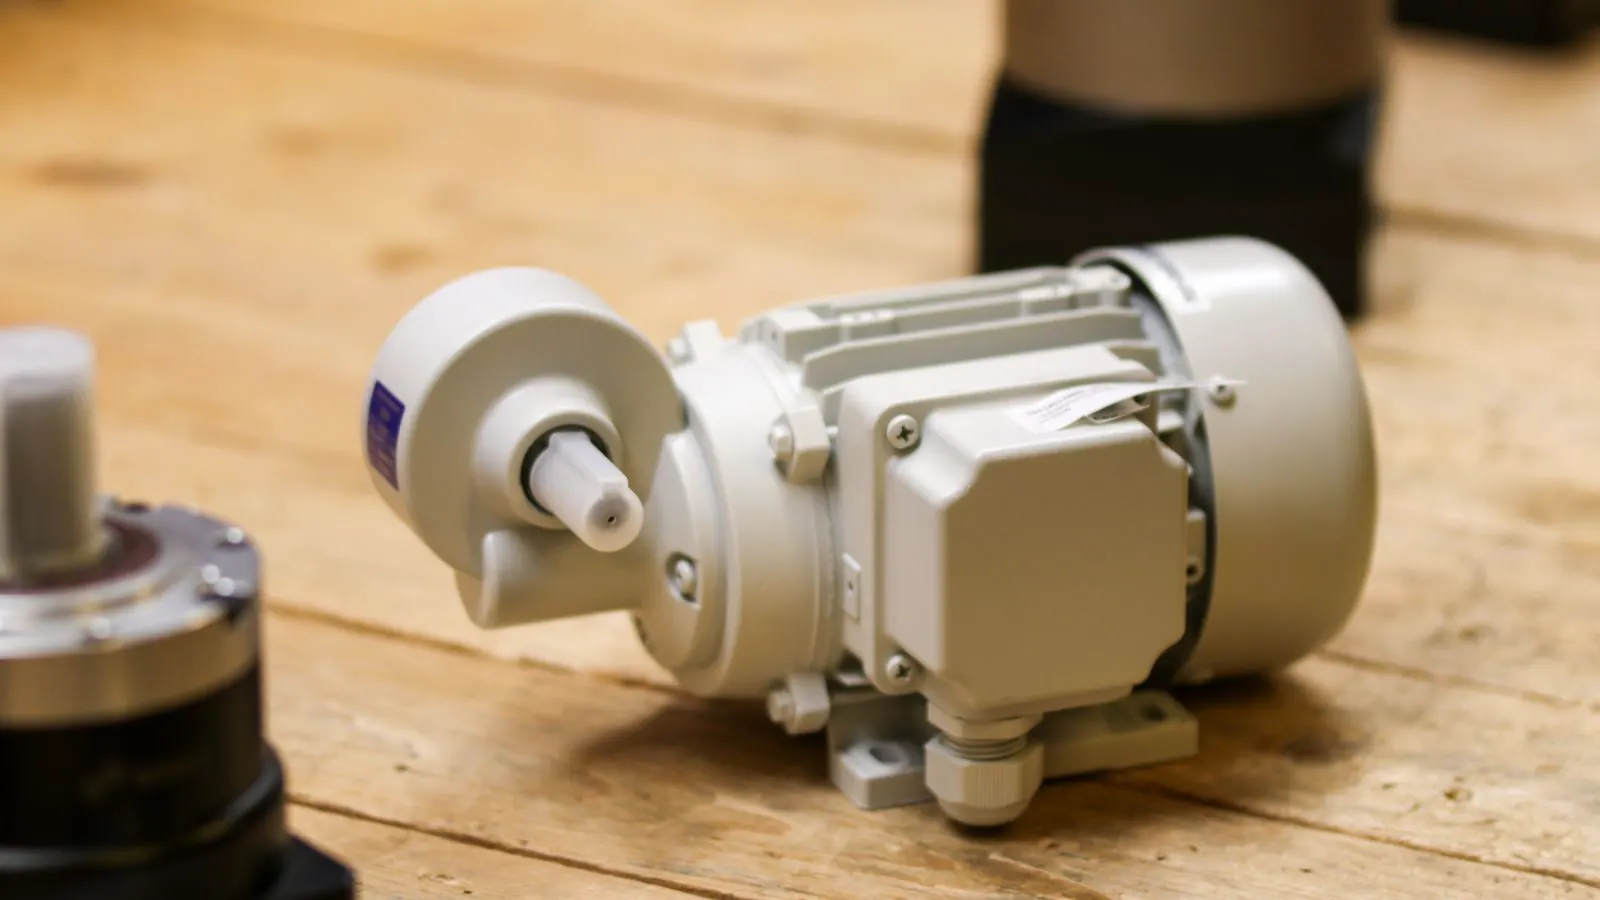
To match gearbox ratios to motor and load speeds, divide the motor's rated speed by the required output speed. Verify the result against torque, thermal limits, and standard ratio series. Use this method to select motor driven reducers that deliver the correct speed reduction without oversizing or undersizing the drive.
- The basic ratio is found by dividing motor speed by required load speed.
- Always check standard ratio series because exact calculated values rarely exist in catalogues.
- Confirm torque at the output shaft, not just the speed ratio, to protect the reducer.
- Use helical or spur gearboxes based on noise, smoothness, and cost constraints.
- Verify the final output speed with a tachometer or encoder reading after installation.
What you need before you start
Do not start with a catalogue. Start with two numbers from your process. The first is the motor speed in revolutions per minute (RPM). The second is the speed the load requires at the output shaft. If the load is a conveyor belt, a pump, or a machine tool spindle, that speed is defined by process requirements, not by the motor.
You also need the motor torque at its rated speed. If you only know the motor power in kilowatts or horsepower, you can derive torque using the standard power formula. Record the voltage and frequency as well, because the motor speed changes with supply frequency if you use a variable frequency drive.
Finally, identify the load type. A steady load behaves very differently from a shock loaded or intermittent load. This distinction changes how much margin you need when selecting the final ratio and the gearbox frame size.
Step 1: Determine the motor rated speed
Measure or calculate the motor speed. For a standard induction motor running on mains power, the rated speed is slightly below the synchronous speed. For example, a two pole motor on a 50 Hz supply runs at about 2970 RPM, and a four pole motor runs at about 1470 RPM. If you use a variable frequency drive, the speed is whatever you set the drive to.
This number is your starting point. If you use a speed lower than the motor rating, you reduce torque availability. If you use a speed above the rating, you risk overheating and mechanical stress. The motor nameplate gives the rated speed, but the actual running speed under load can differ by a small percentage. Use the nameplate value for initial calculations and verify with a tachometer during commissioning.
Step 2: Determine the required output speed
The load speed is the number that matters most in this calculation. If the application requires 15 RPM at the output shaft, that is your target. Do not guess. Measure the existing system or refer to the process design document.
Some applications have a speed range rather than a fixed point. In those cases, design for the highest speed in the range. The gearbox must handle the maximum load torque at the lowest speed. This is where the selection often fails if engineers only check the top end of the range.
Step 3: Calculate the theoretical ratio
Divide the motor speed by the required output speed. This gives the theoretical ratio.
Example: A 1470 RPM motor drives a load that requires 30 RPM. The ratio is 1470 divided by 30, which equals 49.
This number is a target, not a final selection. No gearbox will have exactly 49.000. You will find standard ratios near that value, such as 47.5, 49.2, or 51. You must choose the closest standard ratio that meets your speed tolerance.
Step 4: Check the standard ratio series
Every gearbox manufacturer uses a specific series of ratios. These ratios are based on standard gear tooth counts and module sizes. Common series use ratios that step up by a fixed percentage, often around 10 percent between steps.
When you select a ratio from the series, you accept a small deviation from your calculated ideal. For most applications, a 5 percent deviation in speed is acceptable. For synchronous or precision applications, the tolerance is much tighter. You may need a second stage or a special build to meet a narrow tolerance.
Always confirm the ratio is available in the frame size you need. A small gearbox cannot hold the high torque of a large load, even if the ratio is perfect. The frame size and the ratio are linked in the catalogue.
Step 5: Verify the output torque
The ratio changes the speed, but it also changes the torque. Output torque is motor torque multiplied by the ratio, then reduced by efficiency. A helical gearbox is generally more efficient than a spur gearbox, especially at higher speeds. A single stage spur gearbox may lose 15 percent to 20 percent of the input power as heat. A multi stage helical unit may lose 10 percent to 15 percent.
Calculate the output torque. If your load requires 500 Newton meters, and your motor produces 20 Newton meters, you need a ratio of at least 25, assuming 100 percent efficiency. With 85 percent efficiency, you need a ratio of about 29.4. If you select a 27 ratio, the output torque will be insufficient. The motor will stall or overheat.
This is the most common failure point in motor driven reducers. Engineers select the ratio for speed, then ignore the torque check. The gearbox looks correct on paper, but the motor cannot turn the load.
Step 6: Select the gearbox type
Now decide between helical and spur gearboxes. Spur gearboxes use straight teeth. They are cheaper, simpler, and quieter at low speeds. Helical gearboxes use angled teeth. They mesh more smoothly, run quieter at high speeds, and can handle higher power in a smaller package.
For low speed, high torque applications where noise is not a concern, a spur gearbox is often the right choice. For high speed applications or where the environment is noisy, a helical gearbox is better. If the load has shock loads, a heavy duty helical unit with a larger frame and a thicker housing will handle it better.
Do not mix types in a multi stage unit without checking the manufacturer’s compatibility. Some manufacturers offer integrated multi stage helical units. Others offer single stage spur units that can be coupled in series. The coupling method affects the alignment and the service life.
Step 7: Account for the load duty cycle
A load that runs continuously for 24 hours a day has a different thermal profile than a load that runs for 30 minutes a day. The gearbox must be sized for the duty cycle. If you use a standard continuous rating, you may be safe. If you use an intermittent rating, you can use a smaller gearbox.
Check the thermal rating of the gearbox. The heat generated in the gears and bearings must be dissipated by the oil. If the ambient temperature is high, or if the gearbox is in an enclosed space, the oil temperature will rise. A higher oil temperature reduces the viscosity and increases the wear.
If the load has a high starting torque, you must check the starting torque rating of the gearbox. Some gearboxes are rated for continuous torque, but the starting torque can be two or three times higher. If the starting torque exceeds the rating, the gearbox will slip or the motor will stall.
Step 8: Verify the installation and alignment
The ratio calculation is only half the job. The physical installation must support the gearbox. The motor and the gearbox must be aligned correctly. If they are misaligned, the gears will wear unevenly and the bearings will fail early.
Use the manufacturer’s mounting instructions. Some gearboxes are flange mounted. Others are foot mounted. The motor must be mounted to the same base or to a rigid frame. Use a dial indicator or a laser alignment tool to check the shaft alignment. A misalignment of even a small amount will reduce the life of the gearbox.
Check the lubrication. The gearbox needs the correct oil. The oil viscosity changes with temperature. If the oil is too thin, it will not protect the gears. If it is too thick, it will create drag and heat. Follow the oil specification on the nameplate.
Step 9: Final verification after installation
Once the gearbox is installed and the motor is running, measure the actual output speed. Use a tachometer or read the encoder if the motor has one. Compare the measured speed to the calculated speed.
If the measured speed is off by more than your tolerance, check the ratio. Did you select the wrong ratio from the series? Is the motor running at the expected speed? Is the variable frequency drive set correctly?
If the speed is correct, check the temperature. The gearbox housing should be warm to the touch, but not hot. If it is too hot, the load may be too heavy, or the oil may be wrong, or the alignment may be poor. Record the temperature and the speed. These values are useful for maintenance and for future troubleshooting.
Common mistakes to avoid
The most common mistake is selecting the ratio without checking the torque. The speed looks right, but the motor cannot turn the load. The second mistake is ignoring the standard ratio series. You calculate a ratio of 49, but the closest standard ratio is 47.5. The output speed is now 1.5 percent higher than required. In some applications, that is fine. In others, it is not.
The third mistake is using the motor speed at no load. The motor speed under load is lower. If you use the no load speed, you will overestimate the output speed. Use the rated speed from the nameplate, or measure the speed under load.
The fourth mistake is ignoring the duty cycle. A gearbox rated for continuous duty may be fine for a light load, but if the load runs in bursts, the thermal profile is different. Check the duty cycle rating.
The fifth mistake is not checking the alignment. A perfectly calculated ratio will not help if the shafts are misaligned. The gearbox will fail, no matter how good the ratio is.
Final verification checklist
Before you accept the installation, run through this checklist. The motor speed matches the nameplate or the drive setting. The output speed matches the load requirement within tolerance. The output torque is sufficient for the load, including starting torque. The gearbox type is appropriate for the speed and noise requirements. The frame size is large enough for the torque. The duty cycle is within the gearbox rating. The alignment is checked and correct. The oil is the correct type and viscosity. The temperature is within the normal range. The service interval is set.
If you pass all of these checks, the gearbox ratio is matched correctly. If you fail any of them, go back to the calculation and adjust the selection. Do not force a fit. The ratio must be chosen carefully, and the torque must be verified.
Table: Example Ratio Selection
| Motor Speed (RPM) | Required Output (RPM) | Calculated Ratio | Standard Ratio | Resultant Output (RPM) |
|---|---|---|---|---|
| 1470 | 30 | 49.0 | 47.5 | 30.9 |
| 1470 | 15 | 98.0 | 95.0 | 15.5 |
| 2970 | 60 | 49.5 | 51.0 | 58.2 |
| 1470 | 10 | 147.0 | 140.0 | 10.5 |
| 2970 | 30 | 99.0 | 95.0 | 31.3 |
The table shows how the standard ratio affects the final output speed. The calculated ratio is the ideal value. The standard ratio is the closest available value. The resultant output is the actual speed you will get. Check if this speed is within your application tolerance. If it is, you are good. If it is not, you may need a different ratio series or a special build.
How to handle special cases
Some applications have a variable speed requirement. In those cases, the gearbox ratio is fixed, but the motor speed changes. The variable frequency drive changes the motor speed, and the output speed changes proportionally. The ratio remains the same. This is the simplest case.
Other applications have a fixed motor speed and a variable load speed. This is harder. You may need a clutch, a brake, or a variable pitch belt. A standard gearbox cannot change its ratio. If the load speed varies widely, you may need a different transmission method.
Some applications have a very low output speed. For example, 1 RPM or less. Standard multi stage gearboxes may not be able to achieve that ratio in a small package. You may need a worm gearbox or a planetary reducer. Check the torque and the size requirements carefully. A low speed, high torque application often requires a large frame and a heavy duty design.
When to use a helical versus a spur gearbox
The choice between helical and spur gearboxes depends on the speed, the noise, and the cost. Spur gearboxes are simpler. They have fewer parts. They are cheaper to manufacture. They are easier to repair. Helical gearboxes have more parts. They are more expensive. But they run smoother and quieter.
If your application is a conveyor in a warehouse, a spur gearbox is usually fine. The speed is low. The noise is not a problem. The cost is a factor. If your application is a machine tool in a clean room, a helical gearbox is better. The speed is higher. The noise is a concern. The smoothness of the motion is important.
Check the manufacturer’s recommendations. Some manufacturers offer both types in the same frame size. If you need to switch from spur to helical later, you may not be able to. Plan for the type you need from the start.
Final check
The ratio is the first step. The torque is the second step. The installation is the third step. If you skip any of these, the gearbox will fail. Do not rush the selection. Use the data from the motor, the load, and the process. Verify the numbers. Check the standard series. Confirm the torque. Verify the installation. The result will be a motor driven reducer that runs smoothly and lasts for years.
Frequently asked questions
Can I use any gearbox ratio that is close to my calculated value?
Not always. The tolerance depends on the application. For most industrial loads, a 5 percent deviation is acceptable. For precision or synchronous applications, the tolerance is much tighter. Check the process requirement before you select the standard ratio.
How do I calculate the torque if I only know the motor power?
Use the formula: Torque equals power divided by speed. Convert the power to watts and the speed to radians per second. This gives you the torque in Newton meters. Use this value to check the gearbox torque rating.
Does the gearbox type affect the efficiency?
Yes. Helical gearboxes are generally more efficient than spur gearboxes, especially at higher speeds. The efficiency depends on the number of stages and the gear geometry. Check the efficiency rating in the manufacturer's datasheet.
What if the load speed varies?
If the motor speed varies, the output speed varies proportionally. The ratio stays the same. If the load speed varies but the motor speed is fixed, you may need a different transmission method, such as a clutch or a variable pitch belt.
Do I need to check the alignment?
Yes. Misalignment causes uneven wear and early bearing failure. Use a dial indicator or a laser tool to check the shaft alignment. Follow the manufacturer's specifications. A small misalignment can reduce the life of the gearbox significantly.